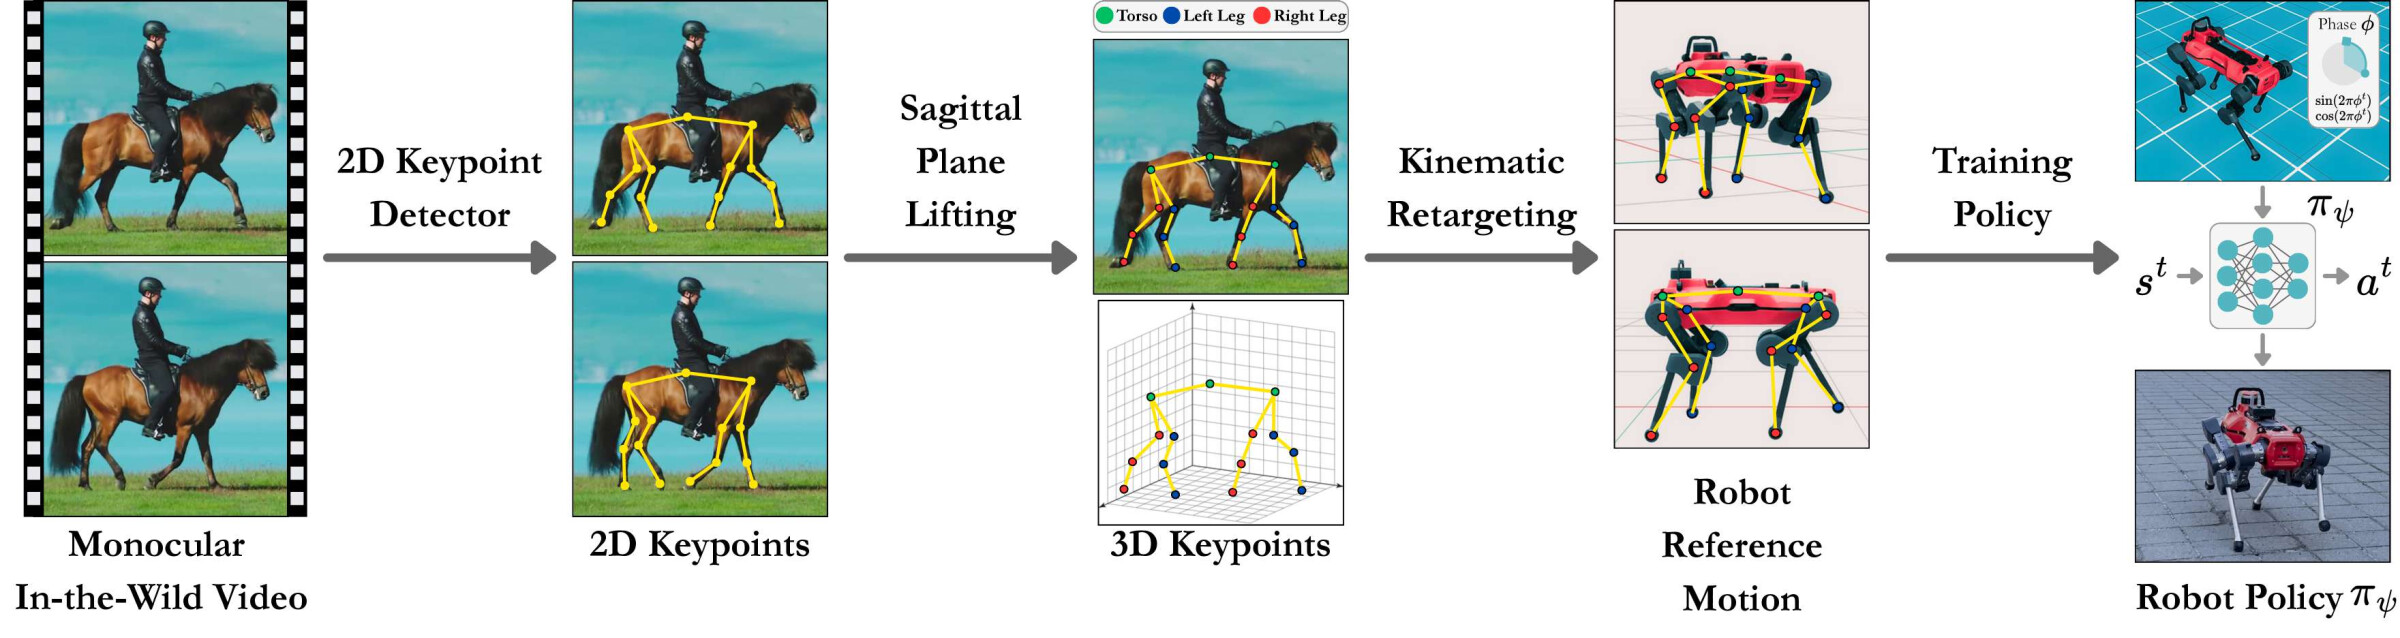
CopyQuad pipeline overview

CopyQuad: Quadrupedal Skill Transfer from a Single Side-View Video Without a Depth Model

Preprint

CopyQuad skips the depth-estimation stage that video-to-robot pipelines usually need. For side-view footage of a walking or trotting animal, it pins the one axis the camera can’t see to the robot’s own stance width, then measures what that costs against real depth models and motion capture.
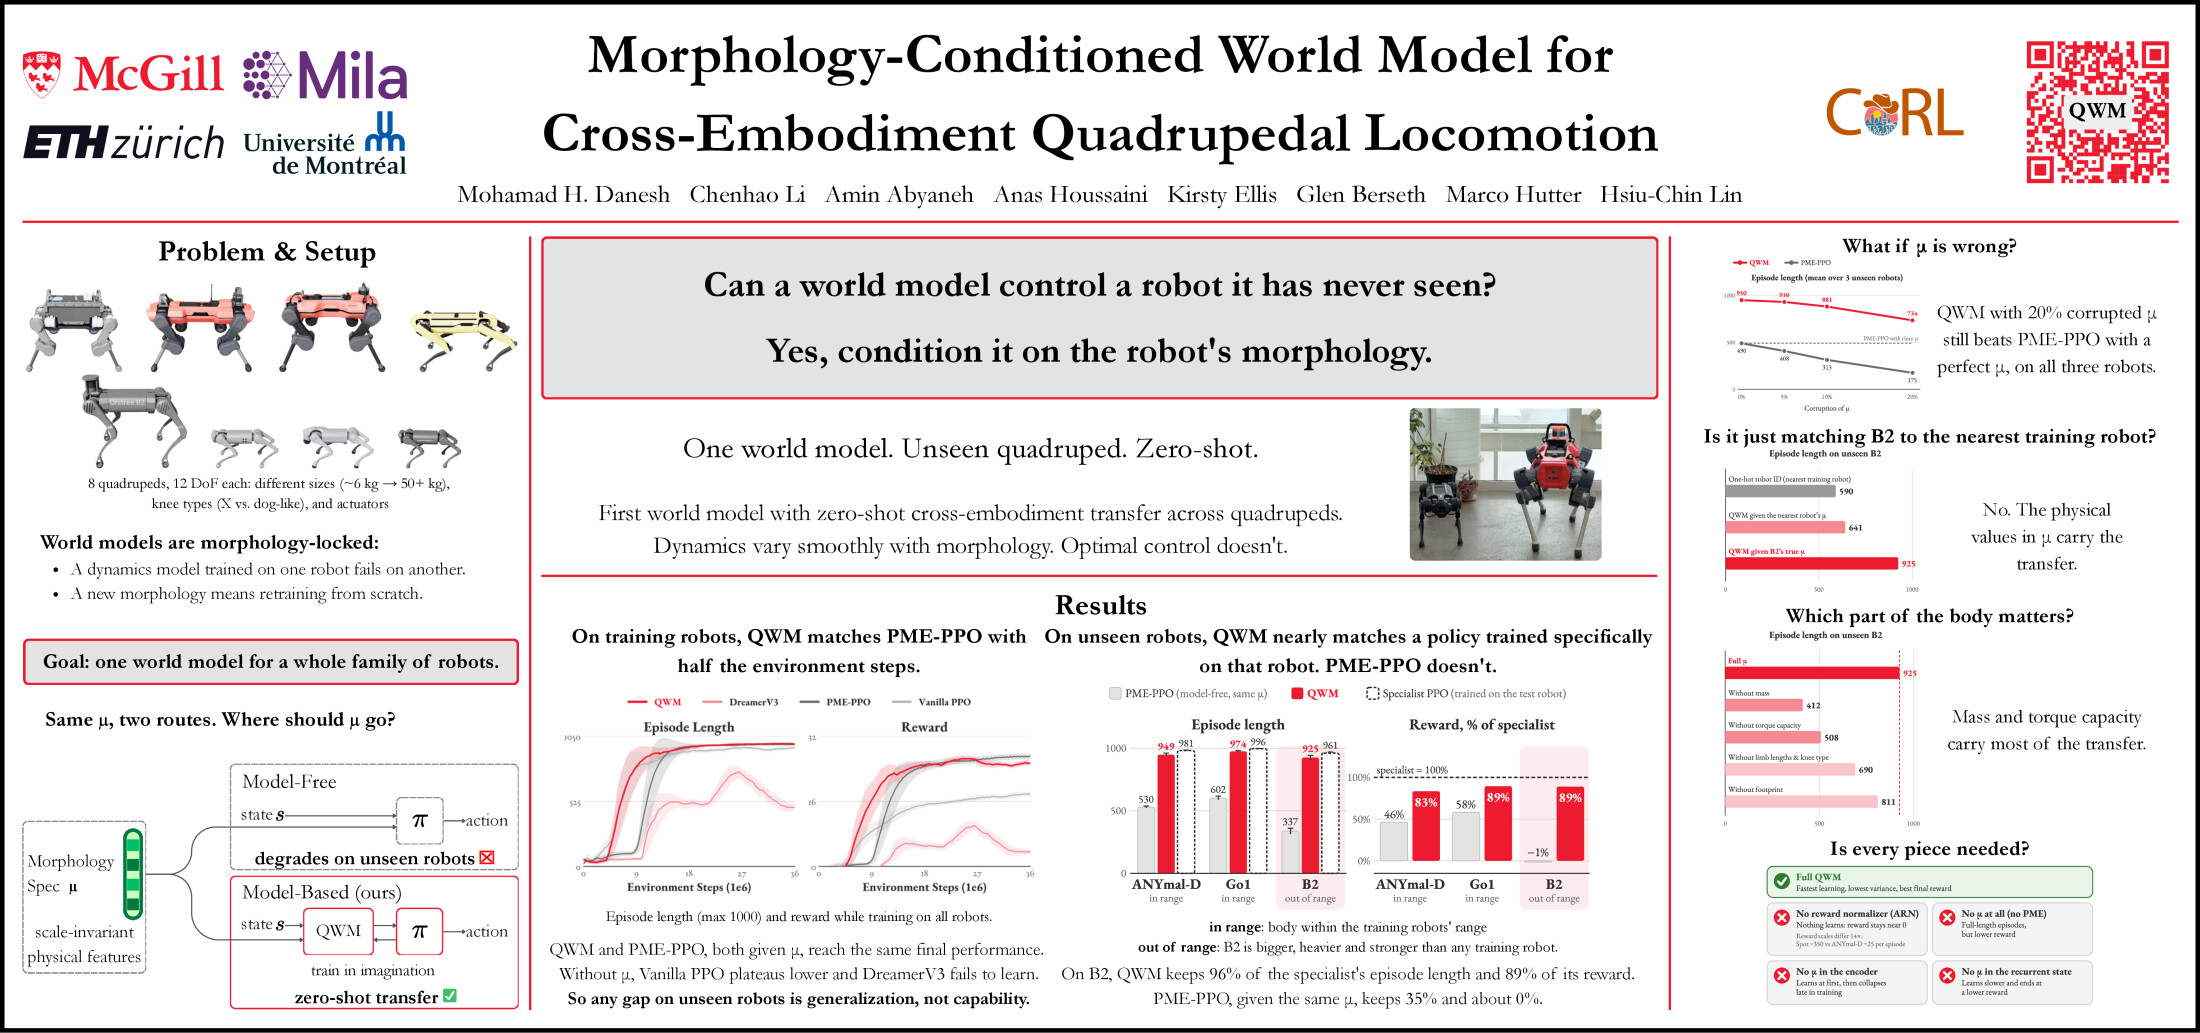
QWM conference poster

Morphology-Conditioned World Model for Cross-Embodiment Quadrupedal Locomotion

CoRL 2026

QWM conditions one world model on scale-invariant physical features and trains every policy inside it. Given the same morphology spec, a model-free policy collapses on unseen robots while QWM transfers zero-shot to new quadrupeds, in simulation and on hardware.