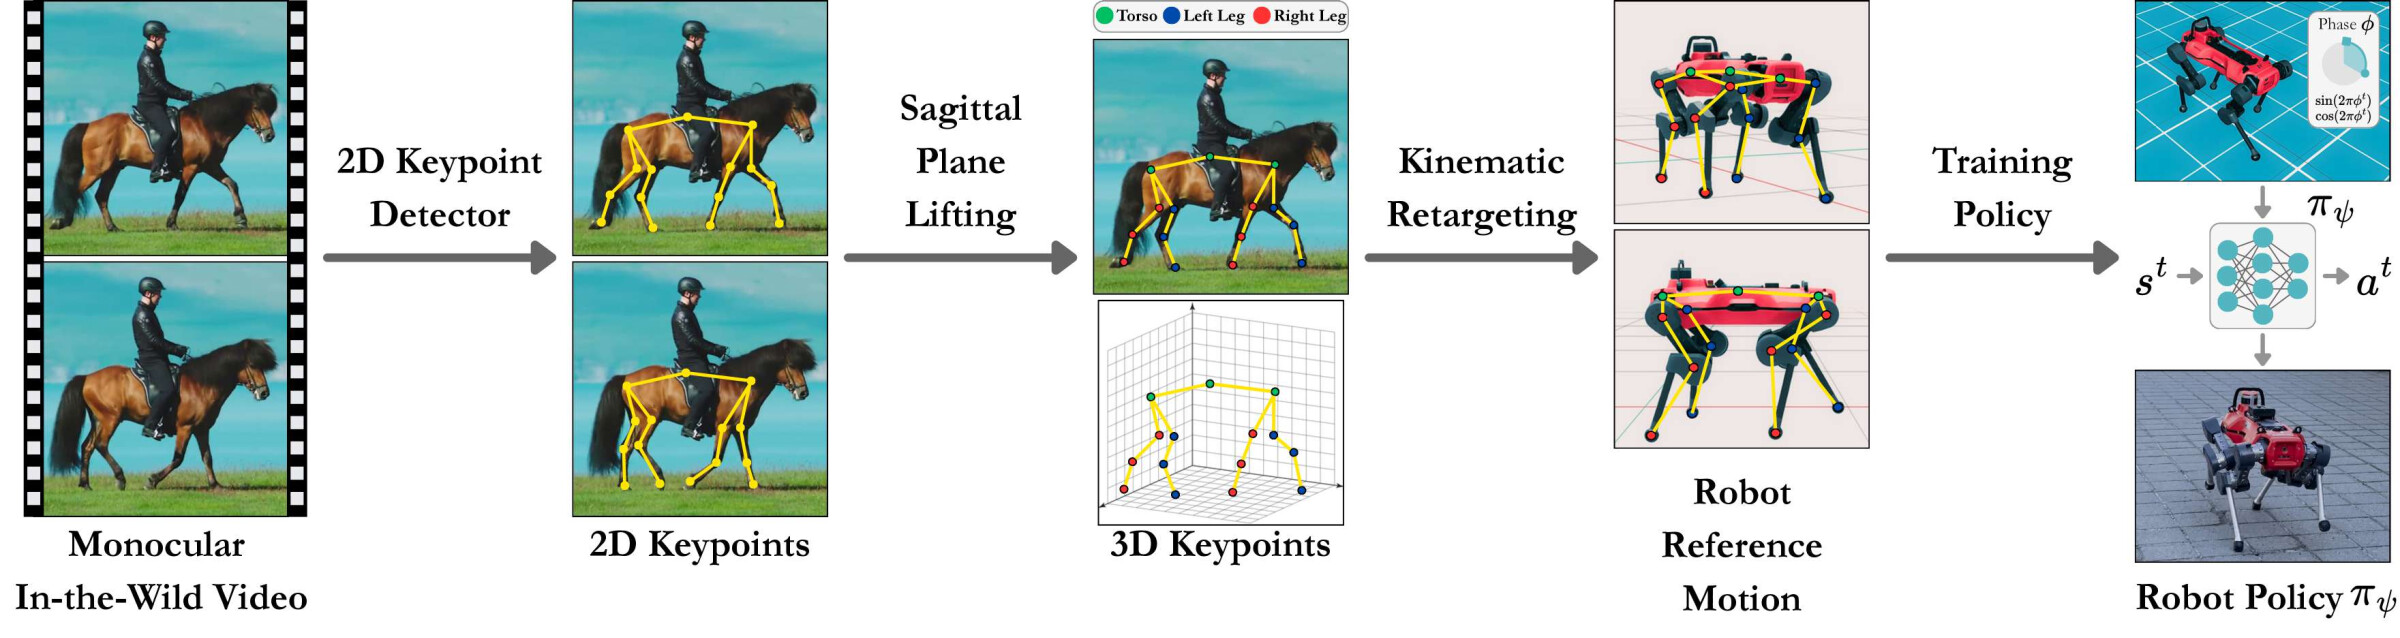
CopyQuad: Quadrupedal Skill Transfer from a Single Side-View Video Without a Depth Model
Preprint
CopyQuad skips the depth-estimation stage that video-to-robot pipelines usually need. For side-view footage of a walking or trotting animal, it pins the one axis the camera can’t see to the robot’s own stance width, then measures what that costs against real depth models and motion capture.